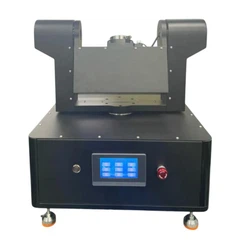
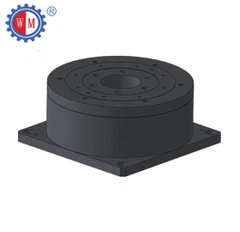
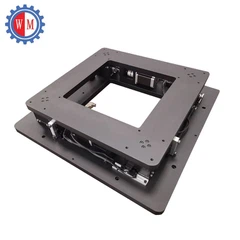
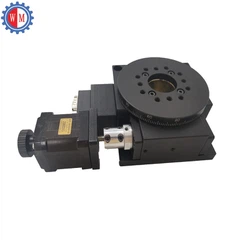
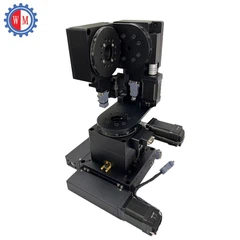
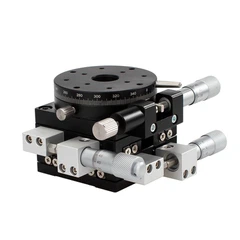


The direct drive motorized rotary table, through its "zero transmission chain" design, has revolutionized the limits of precision, efficiency, and reliability of traditional rotary axes. It excels particularly in scenarios requiring high-frequency start-stop operations, high positioning accuracy, or harsh environments, and has become a core functional component in high-end manufacturing and precision scientific research.
Applications include: Semiconductor wafer dicing/inspection, chip packaging, and OLED panel repair; Fourth/fifth axes in five-axis machining centers (five-axis linkage machining centers), mold engraving, and turbine blade processing; Beam adjustment in synchrotron light sources, surgical robot joints, and cell micro-manipulation platforms.
• Angular-second-level positioning accuracy: The DD motorized rotary stage eliminates backlash and wear issues in traditional mechanical transmission through the adoption of direct drive technology and high-resolution encoders, achieving positioning accuracy up to the angular-second level. This is suitable for ultra-precision scenarios such as semiconductor wafer inspection and optical component alignment.
• High rigidity and low vibration: The direct coupling of the motor rotor and rotary table in our Direct Drive Rotary Tables ensures a compact structure with rigidity increased by over 30% and vibration amplitude below 20 μm/s. This combination makes it ideal for high-dynamic-response applications requiring both precision and power, such as high-speed scanning and fly cutting.
• Maintenance-free and long lifespan: Maintenance-free operation and extended lifespan are inherent to our direct drive motorized rotary table, thanks to its non-contact transmission design that eliminates mechanical wear components. This innovation minimizes downtime and reduces maintenance costs.
• Multi-axis compatibility Direct Drive Motorized Rotation Stage seamlessly supports integration with XY-axis linear motors to form XYθ multi-axis motion platforms, enabling complex trajectory interpolation. This integration capability makes them ideal for applications requiring high-precision, multi-dimensional motion control, such as five-axis machine tools and robotic precision assembly systems.
Features
• Continuous 360° rotation
• Repeatability accuracy of ±2 arcseconds
• Resistance is measured by DC with a standard 0.5m cable.
• with an iron core for high efficiency.
• Encoder Parameters: The value outside the parenthesis is based on absolute encoder is based on absolute encoder (S305) with the standard runout. (S405) with the standard runout.
Specification for Direct Drive Motorized Rotary Stages
|
XD120-71 |
||||
|
Performance Parameters |
Symbol |
Unit |
Series |
Parallel |
|
Continuous Torque (NC) @100°C |
Tcn |
Nm |
3.4 |
3.4 |
|
Peak Torque |
Tpk |
Nm |
10.0 |
10.0 |
|
Torque Constant 士10% |
Kt |
Nm/Arms |
3.0 |
1.5 |
|
Back EMF Constant 士10% |
Ke |
Vpeak/rpm |
0.26 |
0.13 |
|
Motor Constant @25°C |
Km |
Nm/Sqrt(W) |
0.64 |
0.64 |
|
Resistance (L-L)@25°℃ 士10% |
R25 |
Ω |
15.2 |
3.8 |
|
Inductance(L-L)士20% |
L |
mH |
47.7 |
11.9 |
|
Electrical Time Constant |
Te |
ms |
3.1 |
3.1 |
|
Continuous Current (NC) @100°C |
Ice |
Arms |
1.1 |
2.2 |
|
Peak Current |
Ipk |
Arms |
3.9 |
7.8 |
|
Continuous Power Dissipation (NC) @100°c |
Pcn |
W |
36.4 |
36.4 |
|
Max. Coil Temperature |
Tmax |
℃ |
100 |
100 |
|
Thermal Dissipation Constant (NC) |
Kthn |
W/℃ |
0.5 |
0.5 |
|
Max. Bus Voltage |
Ubus |
Vdc |
600 |
600 |
|
Pole Number |
2p |
- |
14 |
14 |
|
Max. Speed @Continuous Torque |
Ωmax |
rpm |
1700 |
2000 |
|
Max. Speed @Peak Torque |
Ωmax |
rpm |
1400 |
2000 |
|
Mechanical Parameters |
||||
|
Overall Mass (NC) |
mn |
kg |
3.1 |
3.1 |
|
Rotor inertia |
Jr |
kg·m |
1.18E-03 |
1.18E-03 |
|
Axial Runout |
- |
μm |
20(10) |
20(10) |
|
Radial Runout |
- |
μm |
20(10) |
20(10) |
|
Max. Axial Load (Upright Mounting) |
- |
N |
500 |
500 |
|
Max.Axial Load (inverted /Wall Mounting) |
- |
N |
150 |
150 |
|
Max. Moment Load(Upright Mounting) |
- |
Nm |
30 |
30 |
|
Max.Moment Load (inverted/Wall Mounting) |
- |
Nm |
10 |
10 |
|
Encoder Parameters |
||||
|
Absolute Encoder |
- |
bit |
23 |
23 |
|
Communication Protocol |
- |
BISS-C |
BISS-C |
|
|
Accuracy after Error Mapping |
- |
arc sec |
±4(±3) |
±4(±3) |
|
Accuracy without Error Mapping |
- |
arc sec |
±20(±15) |
±20(±15) |
|
Repeatability |
- |
arc sec |
±2(±1.5) |
±2(±1.5) |
|
XD160-77 |
||||
|
Performance Parameters |
Symbol |
Unit |
Series |
Parallel |
|
Continuous Torque (NC) @100°C |
Tcn |
Nm |
9.4 |
9.4 |
|
Peak Torque |
Tpk |
Nm |
27.0 |
27.0 |
|
Torque Constant 士10% |
Kt |
Nm/Arms |
5.8 |
2.9 |
|
Back EMF Constant 士10% |
Ke |
Vpeak/rpm |
0.5 |
0.25 |
|
Motor Constant @25°C |
Km |
Nm/Sqrt(W) |
1.24 |
1.24 |
|
Resistance (L-L)@25°℃ 士10% |
R25 |
Ω |
14.9 |
3.7 |
|
Inductance(L-L)士20% |
L |
mH |
92.1 |
23.0 |
|
Electrical Time Constant |
Te |
ms |
6.2 |
6.2 |
|
Continuous Current (NC) @100°C |
Ice |
Arms |
1.6 |
3.2 |
|
Peak Current |
Ipk |
Arms |
5.8 |
11.5 |
|
Continuous Power Dissipation (NC) @100°c |
Pcn |
W |
74.0 |
74.0 |
|
Max. Coil Temperature |
Tmax |
℃ |
100 |
100 |
|
Thermal Dissipation Constant (NC) |
Kthn |
W/℃ |
1.0 |
1.0 |
|
Max. Bus Voltage |
Ubus |
Vdc |
600 |
600 |
|
Pole Number |
2p |
- |
14 |
14 |
|
Max. Speed @Continuous Torque |
Ωmax |
rpm |
850 |
1000 |
|
Max. Speed @Peak Torque |
Ωmax |
rpm |
550 |
1000 |
|
Mechanical Parameters |
||||
|
Overall Mass (NC) |
mn |
kg |
6.1 |
6.1 |
|
Rotor inertia |
Jr |
kg·m |
4.15E-03 |
4.15E-03 |
|
Axial Runout |
- |
μm |
30(10) |
30(10) |
|
Radial Runout |
- |
μm |
30(10) |
30(10) |
|
Max. Axial Load (Upright Mounting) |
- |
N |
750 |
750 |
|
Max.Axial Load (inverted /Wall Mounting) |
- |
N |
225 |
225 |
|
Max. Moment Load(Upright Mounting) |
- |
Nm |
40 |
40 |
|
Max.Moment Load (inverted/Wall Mounting) |
- |
Nm |
12 |
12 |
|
Encoder Parameters |
||||
|
Absolute Encoder |
- |
bit |
23 |
23 |
|
Communication Protocol |
- |
BISS-C |
BISS-C |
|
|
Accuracy after Error Mapping |
- |
arc sec |
±4(±3) |
±4(±3) |
|
Accuracy without Error Mapping |
- |
arc sec |
±20(±15) |
±20(±15) |
|
Repeatability |
- |
arc sec |
±2(±1.5) |
±2(±1.5) |
|
XD200-87 |
||||
|
Performance Parameters |
Symbol |
Unit |
Series |
Parallel |
|
Continuous Torque (NC) @100°C |
Tcn |
Nm |
18.8 |
18.8 |
|
Peak Torque |
Tpk |
Nm |
54.3 |
54.3 |
|
Torque Constant 士10% |
Kt |
Nm/Arms |
9.4 |
4.7 |
|
Back EMF Constant 士10% |
Ke |
Vpeak/rpm |
0.81 |
0.40 |
|
Motor Constant @25°C |
Km |
Nm/Sqrt(W) |
2.13 |
2.13 |
|
Resistance (L-L)@25°℃ 士10% |
R25 |
Ω |
13.0 |
3.3 |
|
Inductance(L-L)士20% |
L |
mH |
121.0 |
30.3 |
|
Electrical Time Constant |
Te |
ms |
9.3 |
9.3 |
|
Continuous Current (NC) @100°C |
Ice |
Arms |
2.0 |
4.0 |
|
Peak Current |
Ipk |
Arms |
7.2 |
14.4 |
|
Continuous Power Dissipation (NC) @100°c |
Pcn |
W |
100.9 |
100.9 |
|
Max. Coil Temperature |
Tmax |
℃ |
100 |
100 |
|
Thermal Dissipation Constant (NC) |
Kthn |
W/℃ |
1.3 |
1.3 |
|
Max. Bus Voltage |
Ubus |
Vdc |
600 |
600 |
|
Pole Number |
2p |
- |
14 |
14 |
|
Max. Speed @Continuous Torque |
Ωmax |
rpm |
520 |
600 |
|
Max. Speed @Peak Torque |
Ωmax |
rpm |
330 |
600 |
|
Mechanical Parameters |
||||
|
Overall Mass (NC) |
mn |
kg |
9.5 |
9.5 |
|
Rotor inertia |
Jr |
kg·m |
1.14E-02 |
1.14E-02 |
|
Axial Runout |
- |
μm |
40(10) |
40(10) |
|
Radial Runout |
- |
μm |
40(10) |
40(10) |
|
Max. Axial Load (Upright Mounting) |
- |
N |
1000 |
1000 |
|
Max.Axial Load (inverted /Wall Mounting) |
- |
N |
300 |
300 |
|
Max. Moment Load(Upright Mounting) |
- |
Nm |
50 |
50 |
|
Max.Moment Load (inverted/Wall Mounting) |
- |
Nm |
15 |
15 |
|
Encoder Parameters |
||||
|
Absolute Encoder |
- |
bit |
23 |
23 |
|
Communication Protocol |
- |
BISS-C |
BISS-C |
|
|
Accuracy after Error Mapping |
- |
arc sec |
±4(±3) |
±4(±3) |
|
Accuracy without Error Mapping |
- |
arc sec |
±20(±15) |
±20(±15) |
|
Repeatability |
- |
arc sec |
±2(±1.5) |
±2(±1.5) |
Mounting Illustration

XD120-71

Test Report of XD120-71

XD160-77

Test Report of XD160-77

XD200-87

Test Report of XD160-77


FAQ
Q1: Are you a trading company or manufacturer?
A: We are a factory producer.
Q2: What is the MOQ?
A: MOQ: 1PCS
Q3: How long is your delivery time?
A: For a standard direct-drive motorized rotation stage, we have one in stock. It needs 30 working days to deliver after payment. For a non-standard direct-drive motorized rotary table, it needs 60 working days after getting payment.
Q4: Do you provide samples? Is it free or extra?
A: Yes, we could offer the DD motorized rotary stage to test, but you need to pay the freight and the direct-drive motorized rotary stage.
Q5: Choose WANMING in China?
1 . Excellent team: Professional structural engineer for Customer Drawing and Samples.
2. Excellent Quality Control: Equipped with Stick Quality control followed by Experienced Engineers.
3. Excellent Cost Saving: Small Trial Lot Order Available.
4 . The leading time is short: We have CNC machines, NC gear Shaving machines,
NC geamillingng, CNC gear grinding Machines, so the quality and production time could be controlled.
5. The accuracy test report is available from the USA API laser interference
Hot Tags: high precision direct drive motorized rotary stages, China, suppliers, manufacturers, factory, customized, wholesale, cheap, low price, in stock, made in China


